
A custom 48V LiFePO4 battery pack for an AGV, AMR or service robot is not selected by capacity alone. The battery must supply acceleration and lifting loads, accept regenerative current, communicate with the vehicle controller, recharge correctly at a docking station and remain mechanically secure through repeated movement and vibration.
We develop project-specific 48V and 51.2V lithium iron phosphate battery systems for mobile automation. Cell format, capacity, continuous and peak current, BMS logic, CAN or RS485 communication, connector, enclosure, mounting and charging strategy are matched to the actual vehicle rather than a fixed catalog shell.
For fleet deployment, the first successful prototype is only the beginning. Production packs must also deliver consistent runtime, state-of-charge reporting, charging behavior and fault response so that maintenance teams can exchange batteries without creating different vehicle behavior from one unit to another.
Why a 48V LiFePO4 Battery Is Commonly Rated at 51.2V
A 48V-class LiFePO4 battery normally uses sixteen lithium iron phosphate cell groups connected in series, known as a 16S configuration. Each cell group has a nominal voltage of approximately 3.2V, giving the complete battery a nominal voltage of about 51.2V. This is why “48V LiFePO4 battery” and “51.2V LiFePO4 battery” are often used for the same voltage platform.
| Voltage term | Typical 16S LiFePO4 value | AGV or robot design implication |
|---|---|---|
| Nominal voltage | Approximately 51.2V | Used for energy, power and runtime calculations |
| Maximum charge voltage | Commonly within 57.6–58.4V, subject to the approved cells and BMS | The drive controller, charger and DC/DC converters must accept the full voltage window |
| Discharge range | Defined by cell limits, vehicle cutoff and BMS settings | The machine must not rely on a universal low-voltage threshold |
| Series configuration | Sixteen cell groups in series | Parallel cells or larger cells increase capacity and current while nominal voltage remains 51.2V |
These figures are engineering references rather than universal charger settings. The final limits follow the selected cell specification, required cycle life, BMS calibration, charger and vehicle electronics. A 13S NMC lithium-ion pack may also be marketed as a 48V battery, but it has a different nominal voltage, maximum charge voltage and discharge profile. Chemistry and series count must therefore be stated clearly in the specification.
The broader term 48V lithium battery does not identify the chemistry or electrical window. An OEM drawing should specify 16S LiFePO4 or 51.2V LiFePO4 so that the BMS, charger and controller are not configured for an incompatible lithium-ion system.
Whether an RFQ uses “48V battery,” “48 volt lithium battery” or “51.2V battery pack,” the supplier should confirm chemistry, series count and maximum charged voltage before proposing a replacement or prototype.
Why 48V Is Useful for Mobile Automation
AGVs and robots combine traction motors with computers, sensors, safety scanners, wireless communication, lifts, conveyors or robotic arms. For the same power, a higher battery voltage reduces current. This can reduce conductor demand and resistive loss, although high peak current, connectors and protection still require careful design.
For example, a 3kW load at 51.2V nominal draws approximately:
3,000W ÷ 51.2V = 58.6A
The same 3kW load at 24V would draw about 125A before allowing for efficiency or voltage variation. Actual battery current changes with acceleration, slope, payload, lift operation, wheel friction, controller efficiency and state of charge. The example explains the voltage-current relationship only; it is not a BMS, cable or fuse selection.
Best-Fit AGV, AMR and Robot Applications
A custom 48V battery pack is suitable when the mobile platform requires a defined electrical interface, enclosure, charging method or communication protocol that a standard battery cannot provide. Typical applications include:
- Warehouse AGVs and autonomous mobile robots
- Material-transfer carts and conveyor-top mobile platforms
- Automated forklifts, pallet movers and compact stackers
- Delivery robots and indoor logistics vehicles
- Cleaning, inspection and security robots
- Service robots with mobile bases or powered attachments
- Tracked UGVs and special-purpose mobile machines
- Robot platforms that use opportunity charging or automatic battery exchange
- Fleet equipment requiring CAN, RS485 or smart BMS integration
The same 48V voltage label can describe very different duty. A lightly loaded indoor robot travelling on smooth floors has different current, vibration and energy requirements from an automated pallet vehicle climbing ramps with a heavy payload. The machine operating cycle must be defined before cell and BMS selection.
Convert the Vehicle Duty Cycle into Battery Requirements
A useful battery specification starts with how the machine works during a complete shift. Motor nameplate power and target runtime are not enough because acceleration, lifting, idling, computer loads and charging opportunities can significantly change energy demand.
| Operating input | Information to provide | Battery design effect |
|---|---|---|
| Vehicle and payload mass | Empty mass, normal payload and maximum payload | Affects traction energy, acceleration current and braking regeneration |
| Route | Distance, speed, floor condition, ramps, stops and turns | Determines energy per mission and peak current frequency |
| Drive system | Motor and controller models, rated power and current limits | Defines continuous, acceleration and stall-current requirements |
| Auxiliary loads | Computer, sensors, lidar, lift, conveyor, pump, lighting and communications | Adds continuous and intermittent energy demand |
| Duty cycle | Mission time, idle time, shifts per day and operating days | Determines daily energy throughput and cycle-life target |
| Regenerative braking | Maximum returned current, duration and operating state of charge | Affects allowable charge current and high-SOC control |
| Charging opportunity | Dock frequency, contact time, available charger power and full-charge schedule | Determines capacity, charge rate and thermal demand |
| Reserve requirement | Minimum remaining runtime before dispatch or return to dock | Prevents normal operation from using the entire theoretical capacity |
Logged voltage, current and power data from an existing vehicle are especially valuable. A current trace shows how long acceleration peaks last, whether they repeat before the cells recover and how much regenerative current returns during braking. This is more useful than selecting a BMS from the motor’s rated current alone.
Capacity, Energy and Fleet Runtime
Capacity is stated in ampere-hours, while nominal energy in watt-hours provides a clearer basis for comparing packs and estimating shift runtime:
Nominal energy (Wh) = 51.2V × capacity (Ah)
| Battery capacity | Approximate nominal energy | Typical engineering focus |
|---|---|---|
| 48V 20Ah | 1.024kWh | Compact robots, short missions and frequent charging |
| 48V 50Ah | 2.56kWh | Balance between runtime, current capability and removable-pack mass |
| 48V 100Ah | 5.12kWh | Longer operation, higher auxiliary loads or less frequent charging |
| 48V 200Ah | 10.24kWh | Heavy platforms, long shifts and higher structural requirements |
| 48V 400Ah | 20.48kWh | Large mobile equipment requiring detailed thermal, lifting and service planning |
A 48V 100Ah LiFePO4 battery has approximately 5.12kWh of nominal energy. Usable energy depends on discharge current, cell temperature, BMS limits, drive-controller cutoff, DC/DC efficiency, aging and operational reserve. Fleet runtime should be validated using the intended routes and payloads rather than calculated from nominal energy alone.
Daily energy throughput also matters. A smaller pack charged several times per shift may complete more partial cycles than a larger pack charged once per day. Capacity and charging strategy should therefore be evaluated together against fleet availability, charger count, heat generation and the desired service interval.
Cell Format, Current Capability and Production Consistency
Cylindrical and prismatic LiFePO4 cells can both be considered for a 48V robot battery. The correct format depends on pack dimensions, current, mass, cycle target, mechanical loading and production quantity.
- Cylindrical cells: Formats such as 26650 or 32700 can provide flexible layouts and distributed current paths. Higher-capacity packs require more cells, welds and parallel connections.
- Prismatic cells: Larger cells can reduce part count in 50Ah, 100Ah, 200Ah and higher-capacity packs. Terminal fastening, compression, insulation and retention must follow the selected cell design.
- Other formats: Pouch or specialized cells may be reviewed when the battery bay is thin or irregular, but swelling allowance and mechanical protection require additional attention.
For fleet use, cell sourcing and grouping criteria should remain controlled across production. Approved cell model, production lot, voltage, capacity, internal resistance and self-discharge criteria help reduce differences between packs. Changes to cell, busbar, BMS or firmware should follow an engineering-change process rather than being introduced silently during repeat orders.
BMS Design for Drive, Lift and Regenerative Loads
The 48V battery management system monitors sixteen series cell groups and coordinates protection with the robot controller and charger. BMS current must be based on the complete duty cycle, including traction, lifting, steering, startup, stall conditions and auxiliary loads.
- Continuous discharge current at the longest high-load operating condition
- Acceleration and lift peak current, including pulse duration and repetition frequency
- Motor-controller current limit and expected stall behavior
- Continuous and peak regenerative charge current
- Docking-charger current and maximum allowed cell charge rate
- Cell overvoltage and undervoltage limits
- Discharge overcurrent, charge overcurrent and short-circuit response
- Temperature sensors on representative cells, BMS and high-current connections
- Cell balancing behavior and balance-current requirement
- State-of-charge estimation, sleep current and storage behavior
- Contactor or MOSFET control, precharge and wake-up sequence where required
- Fault logging, warning, derating and shutdown logic
If the drive controller contains large input capacitors, connection can create a significant inrush current. A precharge circuit or controlled connection sequence may be required depending on the load capacitance, connector and switching architecture. The BMS overcurrent threshold should not be raised simply to tolerate uncontrolled inrush.
Regenerative braking requires special attention near full charge. If the battery cannot accept the returned current, the BMS may limit or disconnect charging. The vehicle controller should receive an allowable charge-current limit or state-of-charge condition and respond before a hard protection event is necessary.
CAN, RS485 and Robot-Controller Communication
A smart BMS can communicate with the AGV controller, charging station, display, PLC or fleet-management gateway through CAN, RS485, UART or another project-specific interface. Communication allows the machine to manage power and charging before the battery reaches a protective cutoff.
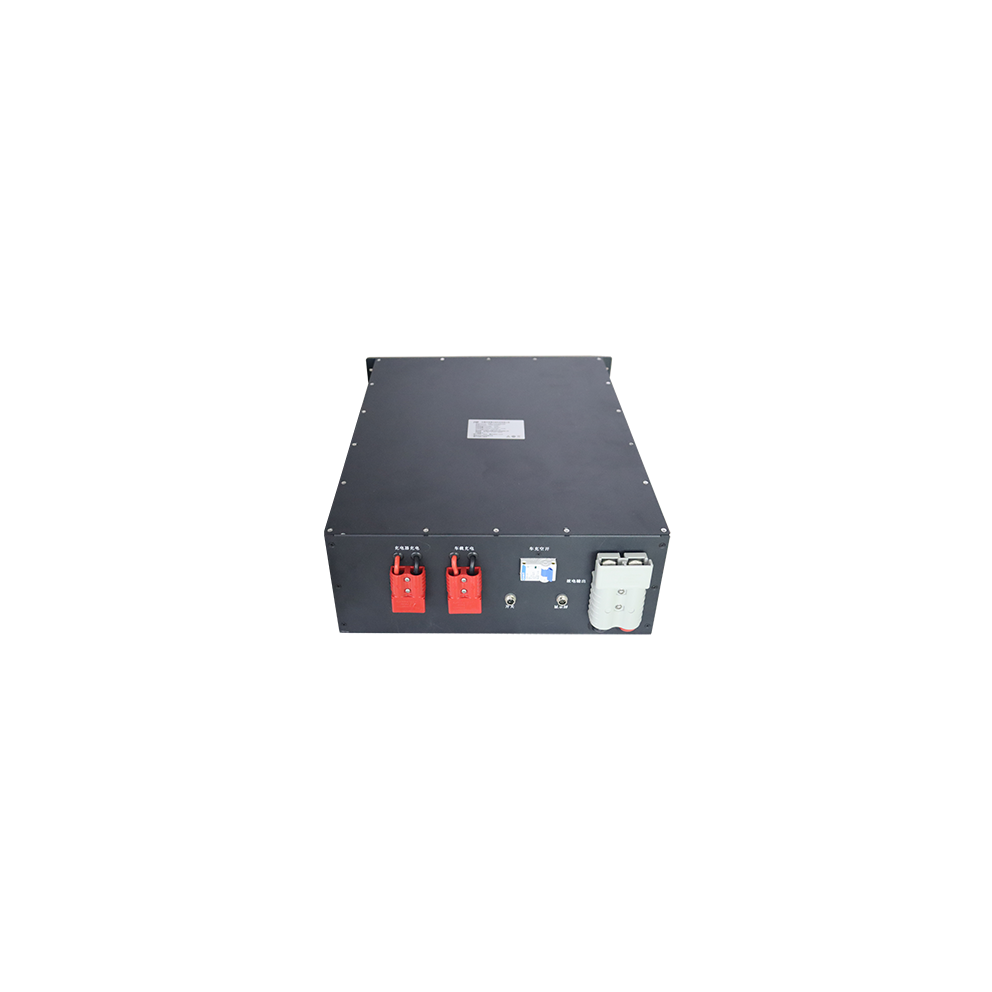
- Pack voltage, current and state of charge
- Individual cell-group voltages and temperature values
- Allowable charge and discharge current
- Charge enable, discharge enable and contactor state
- Warnings, alarms and protection codes
- Remaining capacity, cycle count and state-of-health data where required
- Serial number, hardware version and firmware version
- Charger request, charge stage and charge-complete status
Specifying only “CAN communication” is not enough. The teams must agree message identifiers, bit definitions, scaling, byte order, update rate, timeout, bus speed, termination, node addressing and recovery behavior. If an existing controller or charger is used, provide its protocol document or DBC file before BMS software development is completed.
Loss of communication also needs a defined response. Depending on the vehicle risk assessment, the robot may continue temporarily at reduced power, stop accepting charge, return to a safe location or perform a controlled shutdown. A sudden battery disconnect should not be the normal response to every communication timeout.
Docking Charge and Opportunity-Charging Design
An automatic charging system connects the battery, vehicle and charger as one control sequence. The mechanical contacts must align reliably, the electrical interface must remain within its current and temperature rating, and charging should start only after the required connection and communication conditions are confirmed.
A 48V LiFePO4 battery charger for a docking station must match the approved 16S charge voltage, maximum charge current and BMS control strategy. Charger selection also includes connector sequencing, output isolation behavior, communication and restart after an interrupted charge.
- Dock frequency: How often the vehicle reaches a charger and how long each charging window lasts
- Charge current: Maximum charger output, battery acceptance limit and connector rating
- Handshake: Vehicle presence, charger enable, BMS limits and charge-complete behavior
- Contact monitoring: Temperature, voltage drop, wear, contamination and incomplete engagement
- State-of-charge target: Whether each stop performs a partial charge or the fleet periodically receives a full balancing charge
- Traffic strategy: Charger availability, queue time and reserve energy needed to reach another dock
- Fault recovery: Behavior after power loss, communication timeout, interrupted charging or BMS protection
Opportunity charging can reduce the capacity required on each vehicle, but higher charging frequency and current can increase heat and place more demand on connectors and charger infrastructure. The correct balance is based on daily energy consumption, fleet size, charging-window length and required availability.
Removable Battery, Handle, Guide Rail and Quick Connector
A removable battery can reduce vehicle downtime, but the pack must be designed as a handled machine component rather than a loose box. Weight, lifting method, insertion direction, guide features, latch, connector engagement and operator access must all be reviewed.
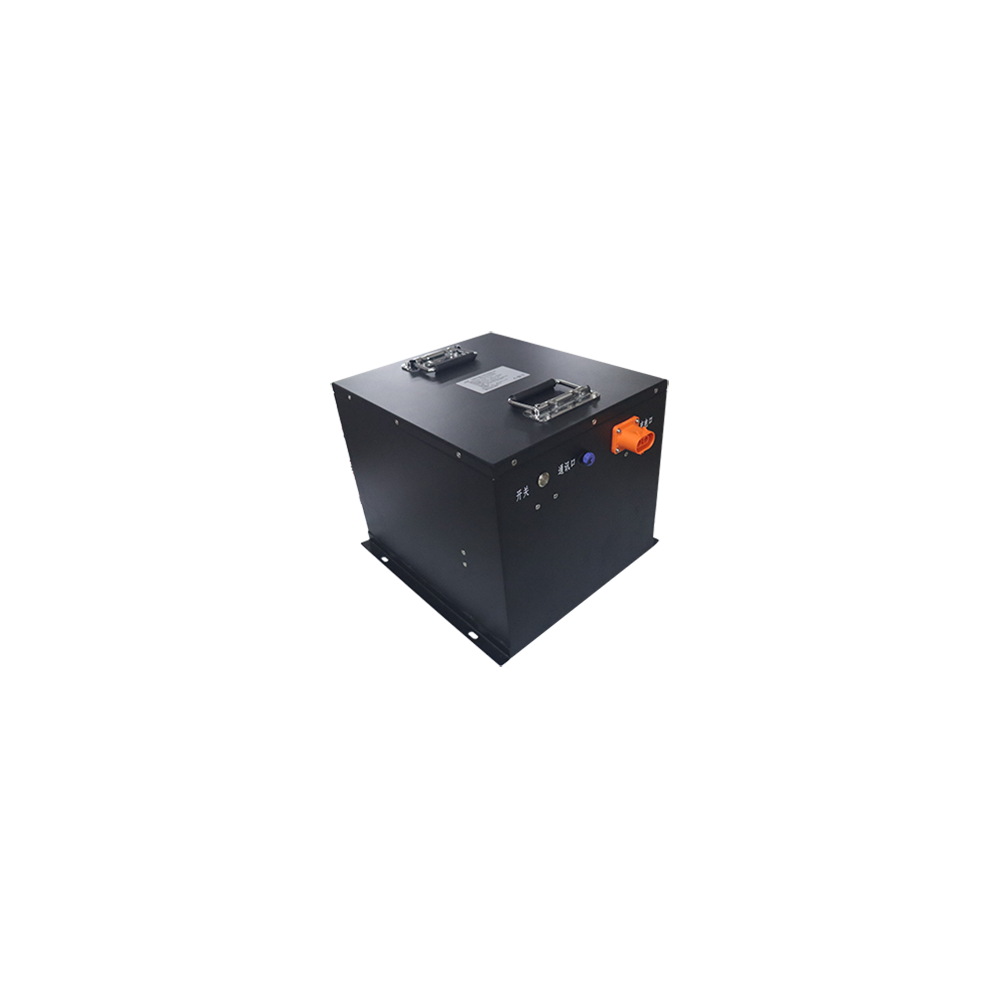
- Handle number, position and load rating based on pack mass
- Guide rail or locating pins that prevent incorrect insertion
- Mechanical latch or locking feature that resists vibration and impact
- Keyed power and signal connectors that prevent incorrect mating
- Connector sequencing or interlock where power must not be live during removal
- Protected contacts that reduce accidental touch and short-circuit risk
- Service labels, serial number and clear orientation marking
- Accessible fuse or disconnect where required by the maintenance plan
Blind-mate connectors should not carry the battery weight or correct major alignment errors. The mechanical guides should position and support the pack before the electrical contacts fully engage. A battery-exchange process should also prevent a partially latched pack from powering the vehicle.
Mechanical Structure, Vibration and Environmental Protection
The enclosure supports cells, busbars, BMS, contactors, fuses, cables and connectors while protecting them from the mobile platform environment. Metal enclosures can provide structural strength and mounting flexibility, while plastic or shrink-wrapped constructions may suit smaller protected battery bays. The choice follows impact, vibration, ingress, corrosion, mass and service requirements.
- Cell retention and compression appropriate to the selected cell format
- BMS and component mounting that resists repeated vehicle vibration
- Insulated and supported busbars, terminals and sensing harnesses
- Strain relief for heavy power cables and frequently handled connectors
- Mounting points that transfer load into the vehicle frame without distorting the enclosure
- Clearance for cable bend radius, handles and service access
- Defined sealing for lid joints, fasteners, cable glands, vents and connectors
- Pressure equalization, condensation management and heat rejection
- Corrosion-resistant materials and finishes for warehouse, outdoor or cleaning environments
Battery bay drawings should be reviewed before the robot frame is released. Designing the vehicle first and fitting the battery afterward often produces inaccessible connectors, tight cable bends, poor lifting access or inadequate clearance for vibration isolators.
Thermal Management and Low-Temperature Operation
Heat is generated by cells, busbars, BMS switching devices, contactors, fuses and connectors. Temperature validation should reproduce repeated acceleration, lift operation, regenerative braking and opportunity charging rather than testing only one steady discharge current. Representative hot and cold cell locations should be measured along with high-current components.
Charging and discharging temperature limits are different. Many standard LiFePO4 cells should not be charged below 0°C unless the cell manufacturer permits it under defined conditions. Low-temperature charge cutoff, controlled heating, charger coordination or an approved low-temperature cell can be considered for cold warehouses or outdoor routes.
A sealed enclosure can trap heat and moisture. Ingress protection, pressure equalization, thermal paths and condensation control therefore need to be considered together. The published temperature and ingress ratings apply only after the final enclosure, connector and test conditions are approved.
Fleet Consistency, Traceability and Maintenance
A fleet requires more control than a single prototype. Packs installed in interchangeable vehicles should use the same approved cell, BMS hardware, firmware, calibration, connector pinout and mechanical interface. Where substitutions are necessary, their effect on runtime, state-of-charge estimation, communication and charger compatibility should be validated before production release.
- Approved bill of materials and controlled alternatives
- Cell supplier, model, lot and grouping records
- BMS hardware and firmware version traceability
- Calibration and end-of-line test records
- Pack serial number linked to inspection and production data
- Consistent connector, mounting and communication configuration
- Recorded capacity, internal resistance and self-discharge criteria
- Service history, fault logs and replacement date where required
- Defined storage state of charge and periodic maintenance procedure
State-of-charge accuracy deserves special attention because LiFePO4 has a relatively flat voltage curve through much of its usable range. Current measurement, capacity learning, full-charge reference conditions and software calibration influence the displayed percentage. Fleet dispatch decisions should not depend on an unvalidated SOC value.
Custom 48V LiFePO4 Battery Specification Framework
| Item | Project-specific range or options | How it is confirmed |
|---|---|---|
| Nominal voltage | 51.2V, commonly described as 48V LiFePO4 | 16S cell configuration and vehicle voltage review |
| Capacity | Typically 20Ah to 400Ah | Mission energy, charging opportunity, reserve, space and mass |
| Nominal energy | Approximately 1.024kWh to 20.48kWh across the stated range | Voltage × capacity followed by route and load validation |
| Cell format | Cylindrical, prismatic or project-approved alternative | Current, packaging, vibration, thermal and cycle-life review |
| Current | Project-specific continuous, acceleration, stall, regenerative and charge ratings | Controller data and measured vehicle duty cycle |
| BMS | Smart BMS with protection, SOC, logging and system control as required | Electrical interface, thresholds and fault-response specification |
| Communication | CAN, RS485, UART or project-specific protocol | Protocol or DBC review and integration test |
| Charging | Manual charger, automatic dock or opportunity charging | Charger interface, handshake, charge-rate and fleet strategy review |
| Enclosure | Metal, plastic, shrink-wrapped or sealed industrial structure | Battery bay drawing, mounting and environmental targets |
| Service design | Fixed or removable pack with handles, rails, latch and quick connector | Operator, maintenance and risk-assessment review |
| Documentation | Specification, drawings, UN 38.3 planning, test summary and SDS/MSDS support | Final configuration, application and destination market |
The stated range describes engineering capability rather than universal stocked models. The production specification is issued only after the cell, BMS, charger, communication, connector, enclosure and validation requirements have been approved together.
AGV and Robot Battery Prototype Validation
A robot battery prototype should be tested inside the intended vehicle and charging system. A useful validation plan can include:
- Incoming cell checks: Verify approved model, lot, appearance, voltage, resistance and grouping criteria.
- Assembly inspection: Check polarity, busbars, welds or fasteners, insulation, harness routing, connector pinout and workmanship.
- BMS protection test: Confirm voltage, current, temperature, short-circuit and balancing behavior under agreed conditions.
- Capacity and energy test: Measure delivered capacity and energy using the approved charge and discharge profile.
- Acceleration and lift test: Record voltage sag, current and temperature during representative peak loads.
- Route and payload test: Run typical and maximum missions to verify usable runtime and reserve.
- Regeneration test: Confirm charge-current control during braking and at high state of charge.
- Docking-charge test: Verify alignment, handshake, current, temperature, interruption and charge-complete behavior.
- Communication test: Validate messages, SOC reporting, timeouts, alarms, derating and controlled shutdown.
- Environmental test: Add vibration, shock, thermal cycling, ingress or corrosion testing where required.
- Fleet interchange test: Install representative packs in more than one vehicle and confirm consistent mechanical and electrical behavior.
Acceptance criteria should be agreed before pilot production. Useful records include individual cell-group voltages, current, cell and component temperatures, SOC, protection events, charge data, mission energy and final remaining capacity. Changing a cell, BMS, firmware, connector or enclosure after validation can affect both performance and documentation.
Certification and Export Documentation Planning
Compliance depends on the final battery design, robot application and destination. UN 38.3 addresses lithium-cell and battery transport testing; it does not certify the finished AGV or robot for complete product safety. Industrial secondary lithium batteries may be evaluated against IEC 62619 where applicable, while the final machine can have additional electrical, machinery, functional-safety or market requirements.
Documentation support can include an approved specification, mechanical drawing, wiring diagram, BMS protocol, label information, inspection records, UN 38.3 test planning and test summary, and SDS/MSDS. CE, CB, UL or other claims are confirmed only after the responsible manufacturer, applicable standard, final configuration and test scope are agreed. A preliminary 48V specification is not sufficient evidence for a certification claim.
Information Needed for a Custom 48V Battery Quote
- AGV, AMR, robot or mobile-machine type
- Vehicle mass, normal payload and maximum payload
- Required runtime, missions per shift and operating days
- Average power or logged energy per mission
- Continuous, acceleration, lift and stall-current data
- Regenerative current and braking behavior
- Motor-controller, DC/DC converter and auxiliary-load information
- Battery bay dimensions, weight limit and mounting orientation
- Fixed or removable-pack requirement
- Handle, guide rail, latch and quick-connector requirements
- Charger model, maximum current and docking sequence
- CAN, RS485 or UART protocol, including DBC file where available
- Operating temperature, storage temperature and low-temperature charging requirement
- Vibration, shock, ingress, cleaning and corrosion targets
- Destination market and applicable test or certification requirement
- Prototype quantity, annual fleet demand and project schedule
Battery bay drawings, charger documents, controller datasheets and real current logs can shorten the feasibility review. If the project replaces an existing pack, also provide photos of its label, connectors, mounting, charging contacts and vehicle compartment.
Related Custom Battery Support
Review our complete custom battery pack engineering service, compare available models in the battery product catalog, explore mobile-equipment requirements under battery solutions, learn how production packs are checked through our battery quality control process, or send your AGV or robot battery requirements for an engineering review.
Frequently Asked Questions
Is 48V or 51.2V better for an AGV?
For a 16S LiFePO4 battery, 51.2V is the nominal battery voltage and 48V is the common system-class name. The drive controller, charger and DC/DC converters must be checked against the complete battery voltage range. A different 48V chemistry may require another voltage window.
Can the battery communicate with the robot controller?
Yes. A smart BMS can support CAN, RS485, UART or another agreed interface. The message map, update rate, timeout, bus settings and vehicle fault response must be defined before software approval.
Can a 48V robot battery support automatic docking charge?
Yes. The battery can be designed for an automatic charger, but the charger voltage, current, contacts, communication handshake, temperature limits and interruption behavior must be coordinated with the vehicle and BMS.
Can the pack be removable?
Yes. Handles, guide rails, mounting plates, latches, interlocks and quick connectors can be reviewed. The design must prevent incorrect insertion, incomplete locking and unintended live contact during removal.
How much energy is in a 48V 100Ah LiFePO4 battery?
A 51.2V 100Ah battery has approximately 5.12kWh of nominal energy. Actual usable energy depends on load, temperature, BMS settings, drive-controller cutoff, conversion losses, aging and operational reserve.
How is peak current selected for an AGV battery?
Peak current is selected from measured or specified acceleration, lifting, turning and stall conditions, including pulse duration and repetition rate. Cells, BMS, busbars, cables, connectors and fuse protection must be evaluated together.
How are robot battery samples tested?
Testing can include fit, capacity, route runtime, voltage sag, temperature rise, acceleration peaks, regenerative braking, docking charge, communication, BMS faults, vibration and pack interchangeability. Final validation should use the intended robot and charger.
Can this battery be used across an AMR fleet?
Yes. Fleet deployment should control cell sourcing, grouping, BMS hardware, firmware, calibration, connectors, mechanical interfaces and end-of-line testing so that packs behave consistently across vehicles and repeat orders.
Which export documents can be supported?
Depending on the approved configuration and destination, support can include UN 38.3 test planning and test summary, SDS/MSDS, battery specifications, drawings, labels, BMS communication information and inspection records. Product-safety certification is evaluated separately for the final robot and market.